Robot Generator
Create robots in any form.
Robot Generator is building a new medium for robotics: define a robot's form, expression, voice, and behavior as freely as you create text, images, or video.
Humanoid robotics / Motion lab
G1. Built to move.
Explore Unitree’s original 29-joint model. Choreograph a kung fu sequence, take its structure apart, or describe your next move.
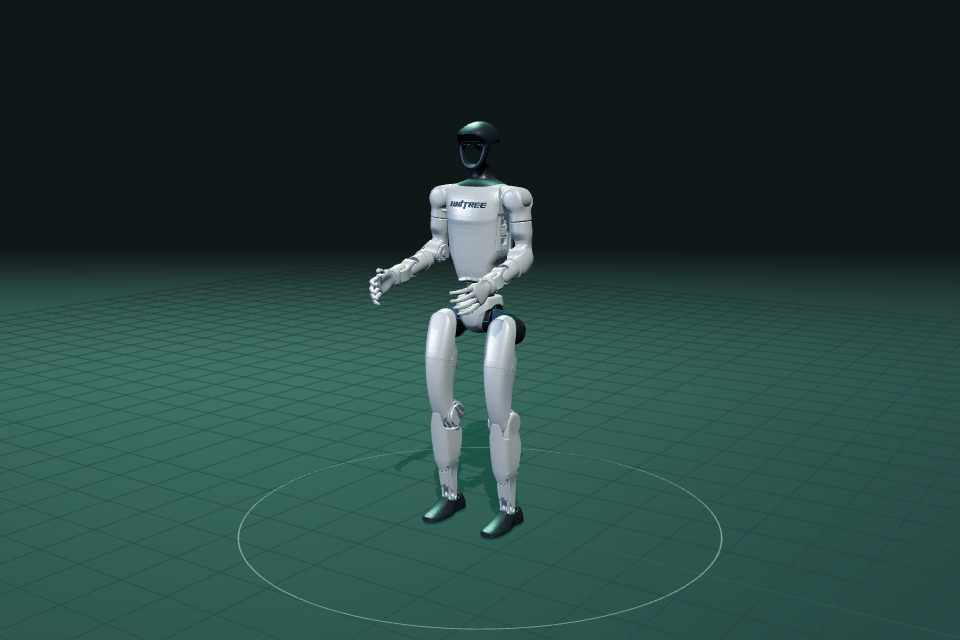
G1 preview · Load the interactive model on demand
Official G1 geometry and joint limits; website-authored kinematic animation. Not a Unitree motion recording, physics simulation or validated hardware controller.
Official model · BSD-3-ClauseEmbodied intelligence / Interactive lab
Meet the SO-101.
Explore the open-source arm used with LeRobot. Orbit the original CAD geometry, move each joint, and see the mechanism come to life.
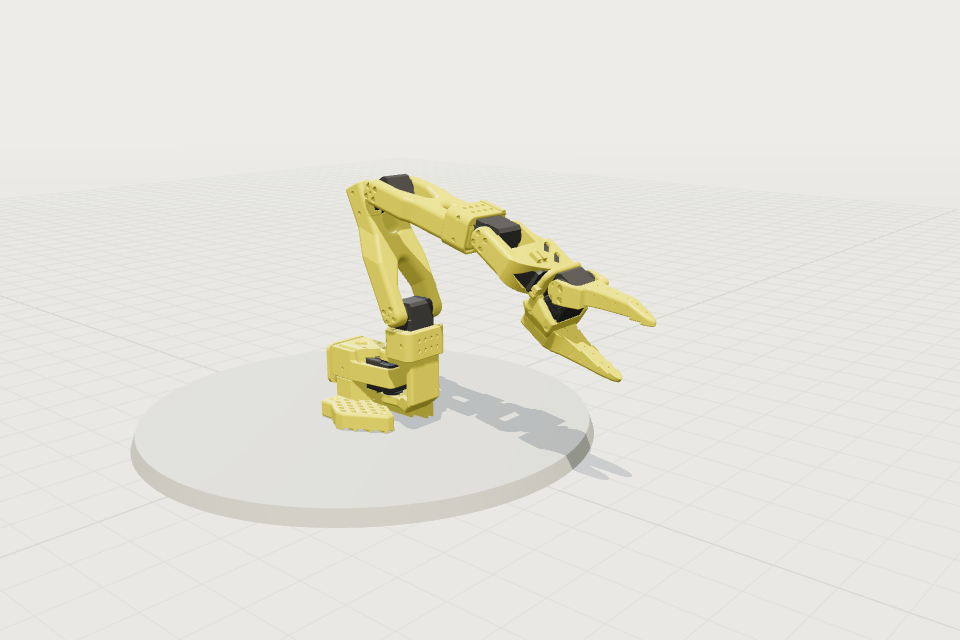
SO-101 preview · Load the interactive model on demand
Original CAD geometry and URDF joint limits. Visual motion only; no collision simulation or hardware connection. Wiring and accessories may differ from a physical build.
Original model / Apache-2.0A new medium for programmable robots
Shape a robot's form, presence, and behavior before it enters the physical world.
Form & appearance
Explore robots that can be sculptural, graphic, textual, animated, or entirely original.
Robot voices
Generate a voice direction that matches your robot's personality, role, and interaction style.
Identity & behavior
Define personality, intent, and interaction patterns as part of the robot's design.
Generative language
Bring the same creative instincts you use for text, images, and video into robotics.
Custom configurations
Save a robot's form, voice, and behavior as a reusable system for new scenes and devices.
From digital to physical
Prepare generated assets and metadata for the applications, simulations, and hardware of tomorrow.
Make robotics as expressive as software.
Start with a concept and turn it into a visual, vocal, and behavioral system before connecting it to the physical world.